


Technical FAQs on torque measurement in focus
 Torque measurement is fundamental to performance validation in motors, drive trains, and mechanical assemblies. While most engineers understand the basic relationship that torque is calculated from a force acting at a right angle via a lever arm, the practical application of a torque transducer in a real test cell requires a deeper understanding of mechanical dynamics, parasitic loads, and metrological precision.
High rotational speeds and massive transient loads require careful integration to protect both measurement integrity and expensive measurement technology.
High rotational speeds and massive transient loads require careful integration to protect measurement integrity and expensive measurement equipment. Beyond the basic formulas, successful implementation must consider transient multipliers, decouple radial and axial loads, and select couplings that are appropriate for the test requirements and setup.
When selecting a torque sensor, engineers must first distinguish between the two main sensor architectures: reaction and rotation sensors.
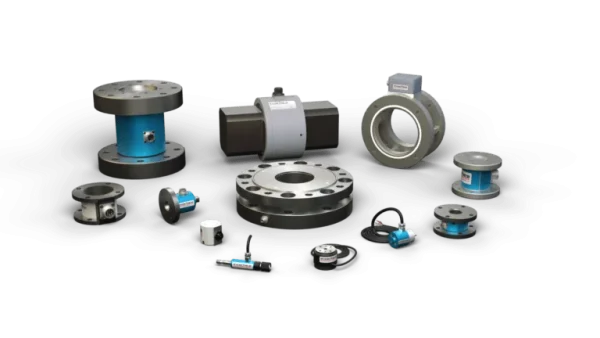
Reaction torque sensors: Stationary, non-rotating sensors that use fixed wiring for signal transmission. They are ideal for static testing or applications with limited rotation (such as valve actuation or fastener testing), provided that adequate strain relief protects the cable from fatigue. See Reaction Torque 101 for more information.
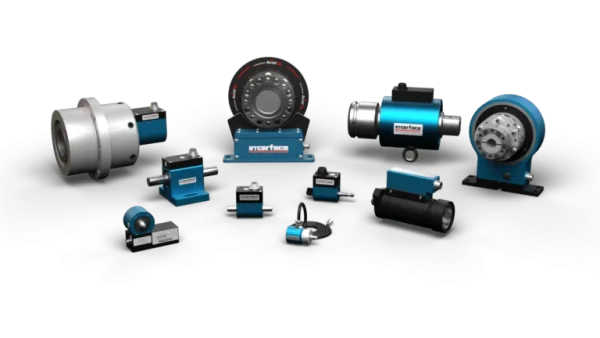
Rotating torque sensors: These are designed for continuous rotation in line with the drivetrain. Since a fixed cable would wrap around the shaft, rotating sensors use special transmission methods such as slip rings, rotary transformers, or wireless telemetry to transmit data from the rotating measuring spring to the stationary measurement system. Further details can be found in Rotary Torque 101.
In addition to hundreds of standard and custom torque sensor configurations in various measuring ranges and form factors, Interface places great emphasis on proven integration practices that separate valuable, usable torque data from the noise of poorly designed test benches or inadequate devices. For a quick overview of common and more technical torque measurement specifications, please refer to our Torque Transducer Cheat Sheet.
TIP: If you would like to delve deeper into fundamental topics of torque measurement, we recommend our Torque 101 webinar, which offers valuable insights into these sensors and their applications.
This article explores the advanced technical aspects of using torque transducers to inform decision-making in testing and measurement. Below, our torque engineers and application experts answer frequently asked questions.
FAQs: Transient loads, capacity selection and overload protection
#1 – What is the most common cause of torque transducer failure?
The most frequent cause of failure is selecting the sensor capacitance solely based on the average operating torque. In real-world drive trains, starting surges, inertia reversals, and transient torque peaks can reach up to ten times the continuous operating torque. Selecting the capacitance based only on steady-state operation often leads to mechanical failure of the measuring spring. Therefore, always calculate the continuous base torque from the power and speed and then apply appropriate service factor multipliers.
#2 – Why must drive and load service factors be applied as multipliers?
Operating conditions vary considerably depending on the drive source and driven load. The constant power output of an electric motor or turbine is relatively uncritical, while the intense torque pulses of an internal combustion engine or piston compressor generate a high cyclic load. Multiplying the continuous torque by drive and load service factors ensures that the measuring spring operates within its fatigue strength. Additionally, soft starters or frequency converters help to control inertia peaks during startup.
#3 – What is the difference between signal clipping and physical overload?
Signal clipping is an electronic limitation where the peak torque exceeds the input measurement range of the measuring device or amplifier. The mechanical sensor remains undamaged, but the peak data is permanently lost because it is clipped. Physical overload, on the other hand, is a mechanical event where the applied torque exceeds the yield strength of the sensor's spring element. This leads to permanent zero-point shifts, loss of calibration accuracy, or catastrophic mechanical failure.
#4 – What compromises arise when using dual-range torque sensors?
Dual-range sensors allow engineers to capture large transient spikes in the primary range while simultaneously resolving fine details in the secondary range. However, the lower range is disproportionately sensitive to temperature-induced zero drift, which can exceed the measurement error for small signals. Furthermore, because the mechanical housing must accommodate the larger overall capacitance, the assembly lacks the compact form factor of a dedicated low-capacitance sensor. For lower-capacitance response sensors, integrated mechanical overload stops should be considered to protect the measuring spring from accidental over-tightening.
#5 – When should multi-axis or axial torsion sensors be used?
Axial-torsion sensors They utilize independent Wheatstone bridge circuits on a single measuring spring to simultaneously measure shear and torsional loads. Since both channels share a single component, the capacitance must be carefully matched: an extreme shear overload can damage the Measuring spring mechanically deform and destroy the torsion bridge in the lower measuring range.
FAQs: Integration, mounting and alignment of sensors
A torque sensor is a precision measuring instrument and must never be used as a load-bearing structural element of the drivetrain. The mounting geometry directly determines the system's service life and measurement accuracy.
#1 – When should floating bearings be used and what couplings do they require?
In a floating or suspended mounting, the sensor is held solely by the drive-side and load-side shaft connections. A flexible retaining strap prevents the stationary housing from rotating, but allows for some compliant movement. This design protects the internal bearings from radial displacement and must be combined with single-flex couplings on both sides.
#2 – When is a base (foot) mounting preferable and what couplings does it require?
Socket-mounted sensors are rigidly bolted to a stationary machine base or base plate. This configuration is particularly suitable for high-speed operation or test benches where test specimens are frequently changed, as the rigid base prevents sagging of the drive train when components are removed. Socket mountings require double-flex couplings on both sides to compensate for parallel and angular shaft misalignment without transmitting strong bending moments to the sensor bearings.
#3 – What is the “stocking fallacy”?
A socket-mounted torque sensor is not a substitute for a pillow block bearing, intermediate shaft, or external support bearing. If the overhanging weight of heavy flywheels, pulleys, or drive motors is supported directly on the sensor shaft, this will destroy the precision bearings inside and cause parasitic crosstalk. To ensure precise centering, precision-machined centering bosses and external support bearings should always be used.
FAQs: Shaft connections, coupling and telemetry
Couplings act as a mechanical safety valve, decoupling the torque sensor from unavoidable angular and parallel misalignment.
#1 – Which shaft connection offers the highest accuracy on test benches?
Smooth shafts combined with precise shrink disc or clamp couplings based on the friction-fit principle are the industry standard. They completely eliminate backlash, distribute clamping forces symmetrically around the shaft circumference, and allow for easy disassembly without damaging the precision-ground surfaces.
#2 – What is the most important technical requirement for the installation of friction clutches?
Shafts and coupling bores must be clean, degreased, and completely dry. Any lubricant, anti-seize agent, or residue will lower the coefficient of friction, preventing the coupling from reaching its rated torque capacity and potentially leading to slippage that could damage the precision shaft.
#3 – Why should keyed shafts generally be avoided in high-precision tests?
Keyed connections are susceptible to fretting corrosion and micro-play under alternating or cyclic torque loads. Over time, wear of the keyway compromises shaft integrity and distorts high-frequency measurements. Furthermore, removing keyed hubs often requires mechanical pullers or localized heating, which can damage the sensor's precision bearings and the adhesive bonds of the strain gauges.
#4 – Which coupling types are recommended for torque transducers?
Torsionally rigid lamellar or bellows couplings are the standard for precision measurements. They offer high torsional stiffness for immediate response to transient processes while remaining compliant enough to compensate for angular and parallel misalignment. Gear couplings and universal joints should be avoided: gear couplings generate backlash and axial thrust forces, while universal joints cause uneven speed fluctuations and additional bending moments.
Video: Torque Sensor Training Part 6 – Torque Couplings
Use our Torque Coupling Selection Guide to compare available options and designs.
#5 – When are telemetry or battery-powered rotation systems needed?
For large, undivided, or continuous drive shafts where installing an inline sensor is mechanically impractical, wireless telemetry collar systems offer a solution. Battery-powered transmitters are particularly advantageous when significant axial shaft misalignment or variable radial distances render inductive energy transfer unreliable.
FAQs: Torque measurement technology, field calibration and measurement uncertainty
Metrological precision ensures that test data is repeatable, traceable, and reliable.
#1 – What is an overhanging bending moment during calibration?
If a calibration arm is mounted directly on a sensor shaft, the test weight attached to the arm end generates both pure torsion and an overhanging bending moment. If the sensor's measuring spring is not designed to suppress off-axis bending loads, the bending stress is transferred to the bridge circuit and distorts the calibration curve.
#2 – Why are square drive connections unsuitable for precision calibration?
Square interfaces exhibit significant mechanical play and shifting load application points. As torque increases, the precise contact point migrates along the square face, altering the effective lever arm length. Flange or precision shrink-disc connections offer the repeatable, rigid geometry required for traceable calibration standards.
#3 – How does the measurement uncertainty budget behave across the measurement range?
The Measurement uncertainty The calibration uncertainty is greatest at the lower end of the sensor's nominal range. Since the total calibration uncertainty is usually expressed as a percentage of the full-scale value, the relative error increases significantly as soon as the measured values fall into the lower ten percent of the range.
#4 – What is the “spirit level fallacy” in calibration arm setups?
If a calibration arm is aligned only along the sensor axis, the arm's deflection under load is disregarded. Since the calibration weights cause the outer end of the arm to deflect downwards, the force vector is no longer perpendicular to the lever arm. This leads to an angular or cosine error, which reduces the effective lever arm length and impairs the validity of the calibration. High-precision calibration devices therefore incorporate angular correction or leveling aids at the load application point.
Integrity of torque measurement as a priority
Precise torque measurement is not just a matter of selecting a high-accuracy sensor, but requires disciplined mechanical integration at the system level. Every factor – from grease-free shrink disc connections to the combination of simple flex couplings with floating bearings – directly impacts measurement accuracy.
Protection against transient peak loads increased by up to ten times, the avoidance of additional bending moments, and the consideration of metrological uncertainty across the entire measuring range ensure that test data remain accurate, repeatable, and reliable.